Lichuan 2A DC Open Loop Stepper Motor Drivers Kit EtherCAT 1.6N.m 2 Phase Nema24 DC24V~50V 4.0A
DC Open Loop Stepper Motor Drivers Kit – EtherCAT NEMA24 2-Phase 24V–50V 4.0A
High-Torque EtherCAT Stepper Motor and Driver Kit for Industrial Motion Control
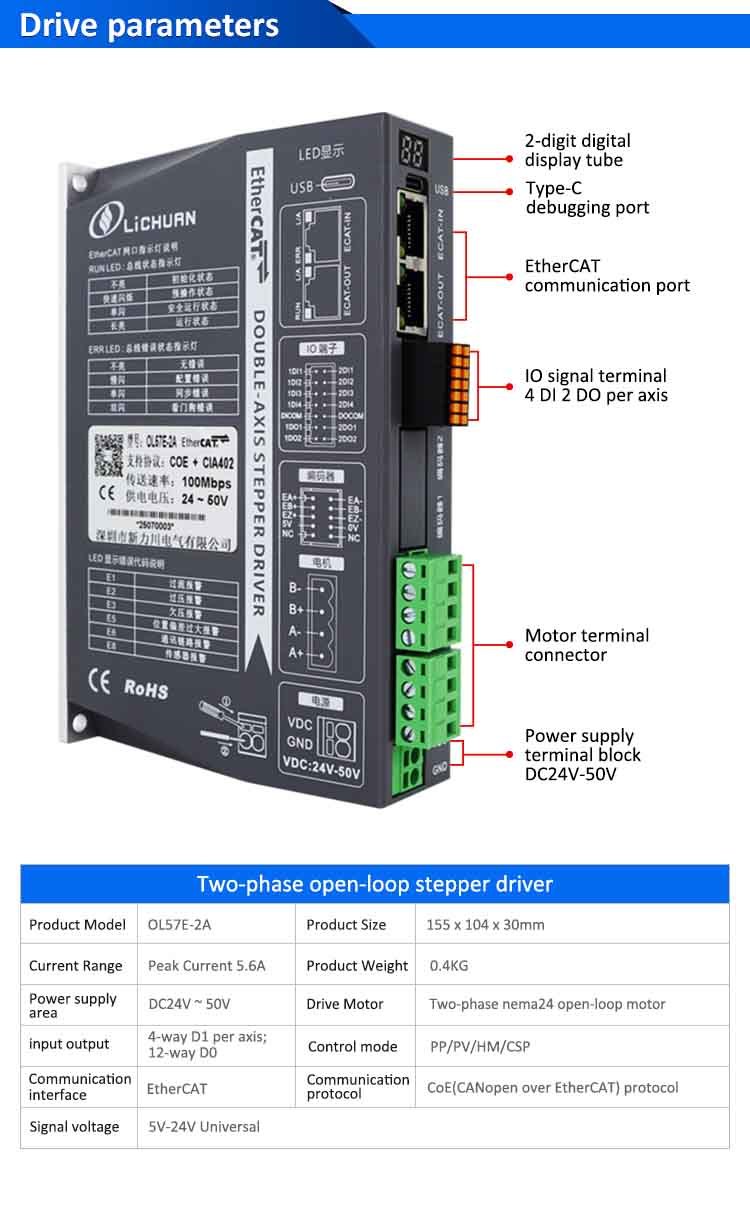
The Lichuan DC Open Loop Stepper Motor Drivers Kit is an EtherCAT-based motion control solution combining a high-torque 2-phase NEMA24 stepper motor with a digital stepper motor driver.
Designed for industrial automation, CNC machinery, positioning equipment and multi-axis motion applications, this DC Open Loop Stepper Motor Drivers Kit offers multiple holding torque options from 1.6 N·m to 4.0 N·m, with a DC24V–50V power supply range and 4.0A drive current configuration.
By combining NEMA24 mechanical performance with EtherCAT network communication, the system is designed to provide a practical, scalable and cost-effective solution for machine builders, OEM manufacturers, automation integrators and professional users.
Product Overview
The Lichuan DC Open Loop Stepper Motor Drivers Kit is developed for applications requiring reliable incremental motion, high holding torque and EtherCAT-based multi-axis communication.
Compared with conventional pulse-only stepper systems, an EtherCAT architecture can simplify multi-axis system integration and provide centralized communication between the motion controller and individual drives.
The NEMA24 stepper motor platform offers higher torque capacity than many compact NEMA17 or NEMA23 systems, making this kit suitable for applications where stronger mechanical output is required without moving immediately to a servo system.
The product is available in several torque configurations:
1.6 N·m / 2.1 N·m / 2.5 N·m / 3.0 N·m / 3.5 N·m / 4.0 N·m
Basic Product Information
| Item |
Specification |
| Product Name |
DC Open Loop Stepper Motor Drivers Kit |
| Brand |
LICHUAN |
| Motor Type |
2-Phase Open Loop Stepper Motor |
| Motor Frame |
NEMA24 |
| Communication |
EtherCAT |
| Input Voltage |
DC24V–50V |
| Drive Current |
4.0A |
| Holding Torque |
1.6 / 2.1 / 2.5 / 3.0 / 3.5 / 4.0 N·m |
| Motor Configuration |
2-Phase |
| Control Architecture |
Open Loop |
| Driver Type |
Digital EtherCAT Stepper Driver |
| Typical System |
Multi-Axis Motion Control |
| Main Applications |
CNC, Automation, Positioning, Robotics |
| Target Customers |
OEMs, Integrators, Distributors, Machine Builders |
Key Features
1. EtherCAT Industrial Communication
The DC Open Loop Stepper Motor Drivers Kit is designed for EtherCAT-based motion-control systems.
EtherCAT communication allows multiple drives to be connected within the same industrial network, making the solution suitable for coordinated multi-axis applications.
For machine builders and automation engineers, this architecture can simplify control-system design compared with large numbers of individual point-to-point motion signal connections.
2. NEMA24 High-Torque Stepper Motor
The NEMA24 motor provides a larger mechanical platform for applications requiring higher torque than smaller stepper motor sizes.
With available holding torque up to 4.0 N·m, the system is suitable for medium- to higher-load positioning applications.
3. Six Torque Options
The DC Open Loop Stepper Motor Drivers Kit is available in six torque levels:
| Torque |
Typical Application Direction |
| 1.6 N·m |
Light to medium positioning |
| 2.1 N·m |
General automation |
| 2.5 N·m |
Medium-load machinery |
| 3.0 N·m |
CNC and industrial positioning |
| 3.5 N·m |
Higher-load motion applications |
| 4.0 N·m |
High-torque NEMA24 applications |
Actual motor selection should consider speed, acceleration, load inertia, transmission ratio, screw lead and duty cycle rather than holding torque alone.
4. DC24V–50V Power Supply
The kit is designed for a DC24V–50V power supply architecture, providing flexibility for different industrial control-panel power configurations.
5. 4.0A Drive Current
The 4.0A driver configuration is designed to provide the current required by the corresponding high-torque NEMA24 stepper motor configuration.
Current settings should always be matched to the selected motor specification.
6. Open-Loop Motion Control
The system operates as an open-loop stepper solution without encoder feedback for continuous position correction.
This makes the system simpler and more economical than encoder-based solutions for applications that do not require closed-loop error correction.
7. Multi-Axis Motion Capability
EtherCAT communication makes the system suitable for machine architectures involving multiple synchronized motion axes.
Typical applications include XYZ positioning systems, CNC equipment, automated assembly machinery and industrial linear-motion equipment.
DC Open Loop Stepper Motor Drivers Kit Technical Specifications
| Parameter |
Specification |
| Product Type |
DC Open Loop Stepper Motor Drivers Kit |
| Stepper Motor |
2-Phase Hybrid Stepper Motor |
| Frame Size |
NEMA24 |
| Holding Torque |
1.6 / 2.1 / 2.5 / 3.0 / 3.5 / 4.0 N·m |
| Driver Current |
4.0A |
| Supply Voltage |
DC24V–50V |
| Communication |
EtherCAT |
| Control Mode |
Open Loop |
| Motor Phase |
2 Phase |
| Motor Driver |
Digital EtherCAT Stepper Driver |
| Motion Application |
Positioning / Speed / Coordinated Motion |
| Typical Equipment |
CNC, Automation Equipment, Robotics, Positioning Systems |
| Installation |
Industrial Equipment / Control Cabinet Integration |
Technical details such as rated current, peak current, inductance, resistance, speed-torque characteristics, dimensions, connector definition and protection functions should be confirmed against the datasheet of the selected motor-driver configuration.
Product Technology
The DC Open Loop Stepper Motor Drivers Kit converts digital motion commands into controlled motor rotation through a sequence of electrical phase currents.
The basic control chain is:
EtherCAT Motion Command → Stepper Driver → Phase Current Control → NEMA24 Motor → Mechanical Motion
The EtherCAT controller sends the required motion information to the driver.
The digital driver processes the command and controls the current supplied to the two motor phases.
The resulting electromagnetic field causes the stepper motor rotor to move in controlled increments.
The motor then transfers the rotary motion to the machine through a lead screw, ball screw, belt drive, rack-and-pinion mechanism or other mechanical transmission.
How Does the DC Open Loop Stepper Motor Drivers Kit Work?
Step 1 – Motion Command
A PLC, industrial PC or EtherCAT motion controller generates the required position, speed or motion command.
Step 2 – EtherCAT Communication
The motion command is transmitted through the EtherCAT network to the designated stepper driver.
Step 3 – Digital Drive Processing
The driver processes the command and controls the motor phase current according to its configured operating parameters.
Step 4 – Electromagnetic Motion
The two-phase NEMA24 motor converts electrical energy into incremental rotary motion.
Step 5 – Mechanical Output
The motor shaft drives the connected mechanical transmission and generates linear or rotary machine movement.
This open-loop architecture is particularly appropriate for applications where high holding torque, repeatability and economical motion control are more important than encoder-based feedback.
Torque Selection Guide
Choosing the correct DC Open Loop Stepper Motor Drivers Kit should begin with the actual mechanical load rather than the motor's maximum torque value.
| Required Torque Range |
Suggested Configuration |
| Up to 1.6 N·m |
1.6 N·m |
| Around 2.0 N·m |
2.1 N·m |
| Around 2.5 N·m |
2.5 N·m |
| Around 3.0 N·m |
3.0 N·m |
| Around 3.5 N·m |
3.5 N·m |
| Up to 4.0 N·m |
4.0 N·m |
For engineering selection, always account for acceleration, target speed, transmission efficiency, load inertia and safety margin.
Product Applications
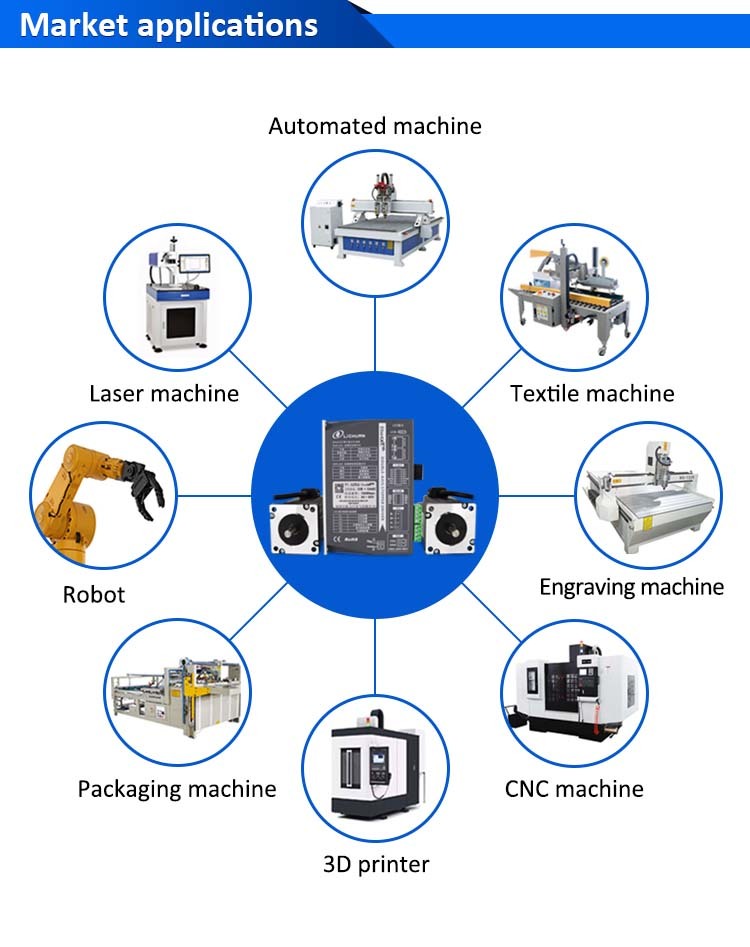
CNC Machines
The high-torque NEMA24 platform is suitable for:
- CNC routers
- CNC engraving machines
- Milling systems
- Woodworking machinery
- Laser engraving equipment
- Cutting machinery
- Industrial engraving systems
Industrial Automation
The DC Open Loop Stepper Motor Drivers Kit can be integrated into:
- Automated production equipment
- Assembly machines
- Packaging machines
- Labeling systems
- Printing machinery
- Inspection equipment
- Material handling systems
- Linear positioning systems
Robotics and Positioning
Typical applications include:
- Cartesian robots
- Linear robots
- Automated positioning units
- Pick-and-place mechanisms
- Gantry systems
- Automated adjustment mechanisms
Digital Manufacturing
The system is also suitable for selected:
- CNC DIY machines
- Laser engravers
- Plotters
- Prototyping equipment
- Digital fabrication systems
- Laboratory automation equipment
B2B Applications and OEM Integration
For OEM manufacturers and machine builders, the DC Open Loop Stepper Motor Drivers Kit can simplify the selection of motor and driver components for new machine designs.
Suitable B2B Customers
Machine Builders
For integrating motion axes into complete equipment.
Automation Integrators
For multi-axis industrial automation projects.
CNC Manufacturers
For feed-axis and positioning systems.
Equipment OEMs
For standardized motion platforms across multiple machine models.
Industrial Distributors
For stocking a family of torque-based NEMA24 EtherCAT motion products.
Engineering Companies
For prototype development and system integration.
Product Advantages
High-Torque NEMA24 Platform
The NEMA24 form factor provides a practical solution for applications requiring more torque than smaller compact stepper systems.
Multiple Torque Configurations
Six torque options make it possible to build a product family for different machine loads without changing the overall NEMA24 platform.
EtherCAT Network Control
The network-based communication architecture is well suited to multi-axis motion systems.
Cost-Effective Open-Loop Architecture
For suitable applications, an open-loop configuration can provide a simpler and more economical alternative to servo-based motion control.
Flexible DC Power
The DC24V–50V supply range accommodates a wide range of industrial DC control architectures.
4.0A Drive Capability
The 4.0A configuration is designed for the corresponding high-torque NEMA24 motor solutions.
Benefits for C-End Users, Makers and CNC Users
The DC Open Loop Stepper Motor Drivers Kit is also suitable for technically experienced CNC builders, makers and automation enthusiasts who need higher torque and EtherCAT communication.
The kit provides:
- NEMA24 mechanical compatibility
- Up to 4.0 N·m holding torque configurations
- 4.0A driver current
- DC24V–50V power architecture
- EtherCAT communication
- Open-loop operation
- Multiple torque choices
- Applications in CNC and automated positioning
Before purchase, users should confirm that their controller or EtherCAT master supports the required communication and drive configuration.
Manufacturing Process
A reliable DC Open Loop Stepper Motor Drivers Kit depends on stable motor manufacturing, electronic assembly and final testing.
Stepper Motor Manufacturing
The motor production process typically includes:
- Magnetic steel lamination processing
- Stator and rotor manufacturing
- Precision copper winding
- Shaft machining
- Bearing assembly
- Rotor and stator assembly
- Mechanical alignment
- Electrical performance testing
Driver Manufacturing
The digital driver production process typically includes:
- Electronic component inspection
- PCB assembly
- SMT soldering
- Firmware programming
- Electrical testing
- Communication testing
- Functional testing
- Burn-in and final inspection
Final Product Inspection
The motor-driver combination is inspected against the relevant product specifications before shipment.
Key inspection areas may include electrical parameters, communication stability, mechanical quality and operating performance.
Installation and Operating Method
1. Confirm the Specifications
Before installation, confirm:
- NEMA24 motor model
- Torque requirement
- Motor current
- Driver current
- DC supply voltage
- EtherCAT controller compatibility
- Mechanical transmission requirements
2. Mount the Motor
Install the NEMA24 motor on a rigid and accurately aligned mounting surface.
Avoid excessive shaft loads or mechanical misalignment.
3. Connect the Power Supply
Connect the DC power supply according to the driver wiring diagram.
Verify voltage and polarity before power-up.
4. Connect the Motor
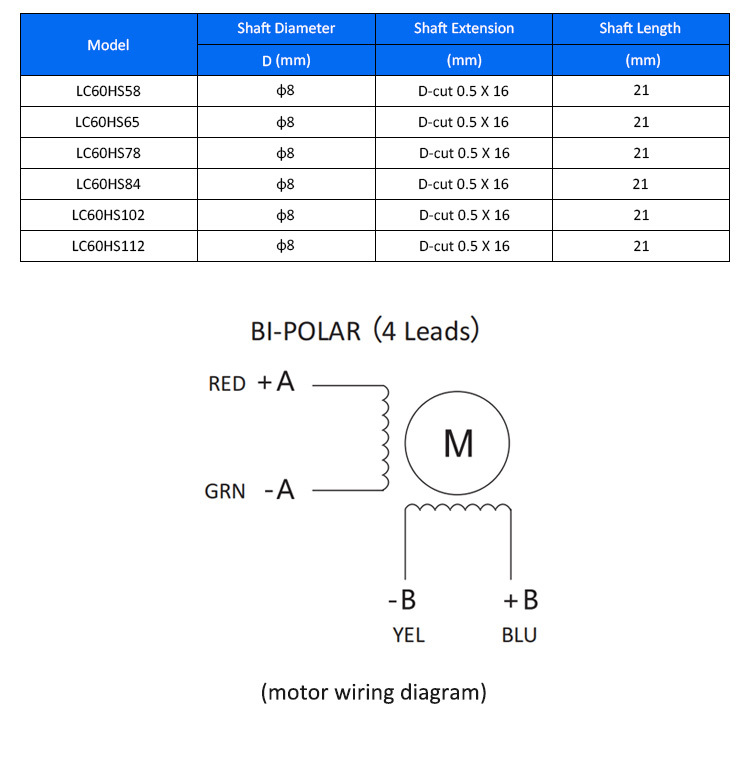
Connect the two motor phases according to the manufacturer's wiring definition.
5. Connect EtherCAT
Connect the EtherCAT communication network between the controller and driver.
6. Configure the Driver
Set the required communication and motion parameters according to the controller and driver documentation.
7. Perform a Low-Speed Test
Run the motor at low speed first.
Check:
- Rotation direction
- Vibration
- Noise
- Communication status
- Mechanical interference
- Motor temperature
8. Start Normal Operation
After confirming stable operation, gradually increase the required speed and acceleration.
Safety Precautions
Power Supply
Use only the recommended DC24V–50V operating range for the applicable product configuration.
Current Setting
Do not exceed the rated current of the selected NEMA24 motor.
Wiring
Always check motor phase wiring and power polarity before energizing the system.
Thermal Management
Maintain adequate ventilation and heat dissipation around the driver.
Mechanical Load
Do not exceed the motor's effective torque capability at the required operating speed.
Open-Loop Limitation
An open-loop system does not continuously verify actual rotor position through encoder feedback. Applications with high external disturbance, extreme acceleration or strict position-error monitoring may require a closed-loop or servo solution.
Open-Loop Stepper vs Closed-Loop Stepper vs Servo
| Feature |
Open-Loop Stepper |
Closed-Loop Stepper |
Servo |
| Encoder |
No |
Yes |
Yes |
| Position Feedback |
No |
Yes |
Yes |
| System Cost |
Lower |
Medium |
Higher |
| Control Complexity |
Lower |
Medium |
Higher |
| Holding Torque |
High |
High |
Application dependent |
| Missed-Step Correction |
No |
Yes |
Yes |
| EtherCAT Available |
Selected Models |
Selected Models |
Common |
| Typical Use |
Cost-Effective Motion |
Higher-Control Motion |
High-Performance Motion |
The DC Open Loop Stepper Motor Drivers Kit is best suited to applications where the advantages of stepper motor technology meet the required positioning and load-performance requirements without requiring closed-loop feedback.
Quality Assurance
Quality control should cover the complete product chain from raw material and motor assembly through PCB production, firmware configuration and final system testing.
Recommended quality-control checkpoints include:
- Incoming component inspection
- Motor winding verification
- Mechanical dimension inspection
- Electrical parameter testing
- Driver function testing
- EtherCAT communication testing
- High/low voltage verification
- Temperature and burn-in testing
- Final visual inspection
- Packaging inspection
For B2B customers, quality documents, test reports and applicable certificates should be supplied according to the actual product model and order requirements.
Product Certificates
Depending on the exact product configuration and target market, available compliance documentation may include:
- CE
- RoHS
- EMC-related documentation
- LVD-related documentation
- ISO9001-related quality documentation
- Applicable product test reports
Certificate availability should be confirmed for the exact NEMA24 motor and EtherCAT driver configuration before making SKU-specific compliance claims.
Product Service
Pre-Sales Support
We can assist customers with:
- Motor torque selection
- Driver matching
- DC24V–50V power selection
- 4.0A current configuration
- EtherCAT system integration
- Multi-axis application evaluation
- CNC motion requirements
- OEM product selection
Technical Support
Support may include:
- Product manuals
- Wiring information
- Parameter configuration
- Motor-driver matching
- Mechanical drawing support
- Application consultation
- EtherCAT integration guidance
B2B Services
For OEMs, system integrators and distributors, services can include:
- Sample orders
- Bulk purchasing
- Product configuration
- OEM/ODM discussion
- Customized packaging
- Technical documentation
- Production coordination
- Export shipment support
FAQ
What is a DC Open Loop Stepper Motor Drivers Kit?
A DC Open Loop Stepper Motor Drivers Kit is a matched motor-and-driver motion-control solution using a DC-powered digital stepper driver and an open-loop stepper motor.
What motor size does this product use?
This product is designed around a 2-phase NEMA24 stepper motor.
What torque options are available?
The product is available in:
1.6 N·m, 2.1 N·m, 2.5 N·m, 3.0 N·m, 3.5 N·m and 4.0 N·m.
What is the input voltage?
The specified operating voltage is DC24V–50V.
What is the driver current?
The specified driver current is 4.0A.
Does the kit support EtherCAT?
Yes. The product is designed as an EtherCAT DC Open Loop Stepper Motor Drivers Kit for industrial motion-control applications.
Is this a closed-loop stepper system?
No. This product uses an open-loop stepper control architecture and does not rely on encoder feedback for continuous position correction.
Can it be used for CNC?
Yes. The high-torque NEMA24 platform is well suited to CNC, engraving, positioning and other automated machinery.
How do I choose between 1.6 N·m and 4.0 N·m?
Consider load torque, operating speed, acceleration, transmission ratio, screw lead, friction and safety margin. The highest holding-torque model is not always the best choice for every axis.
Can the product be used for multi-axis motion?
Yes. EtherCAT communication is particularly suitable for networked multi-axis machine architectures, provided that the EtherCAT master/controller is compatible with the selected driver.
Can I use any PLC?
Not automatically. The controller must provide compatible EtherCAT master functionality and support the communication and motion profile required by the selected driver.
What information should I provide when requesting a quotation?
Please provide:
- Required motor torque
- Power supply voltage
- Number of axes
- Controller or PLC model
- EtherCAT requirements
- Target speed
- Acceleration
- Mechanical transmission
- Estimated order quantity
Why Choose LICHUAN?
LICHUAN focuses on industrial motion-control products and solutions for automation, CNC, positioning and machine-building applications.
The product portfolio is designed to address different levels of machine motion requirements, from stepper motor control to networked and industrial motion-control systems.
For customers looking for a DC Open Loop Stepper Motor Drivers Kit, LICHUAN combines motor selection, driver matching and industrial communication into a practical motion-control product family.
Our objective is to help OEMs, distributors, integrators and technical users reduce component-selection complexity and build reliable motion-control systems more efficiently.
Request a Quote
Find the Right DC Open Loop Stepper Motor Drivers Kit for Your Application
Choose from 1.6 N·m to 4.0 N·m NEMA24 torque configurations with DC24V–50V input and 4.0A drive current.
Send us your application requirements and we can help evaluate the appropriate motor-driver configuration for your machine.
Request a Quote
Contact Our Engineers
Ask for the Datasheet
Request a Sample






|
|
Lichuan 2A DC Open Loop Stepper Motor Drivers Kit EtherCAT 1.6N.m 2 Phase Nema24 DC24V~50V 4.0A Images
|


